Profile photo of Lihan Zha

Robotics • Machine Learning • Generalist Robots

Lihan Zha

I am a PhD student at Princeton University, advised by Prof. Anirudha Majumdar. I also work closely with Prof. Dhruv Shah. I am currently a research intern at Physical Intelligence. I am interested in building generalist robots.

Email: lihanzha [at] princeton [dot] edu

Publications

EgoLAP: Learning from Egocentric Human Data through Language-Action Reasoning

Lihan Zha*, Shresth Grover*, Tenny Yin, Samuel M. Bateman, Hengkai Pan, Mengchao Zhang, Aykut Onol, Allen Z. Ren, Dhruv Shah†, Anirudha Majumdar†

arXiv

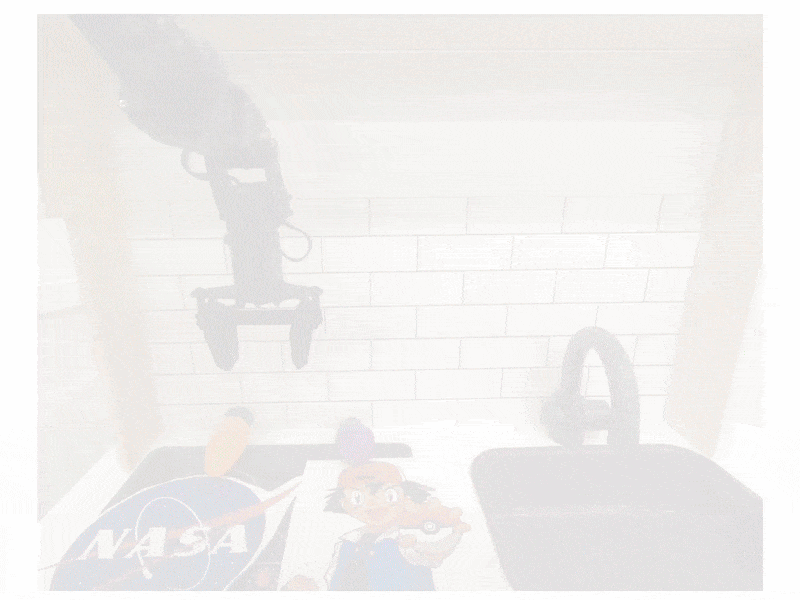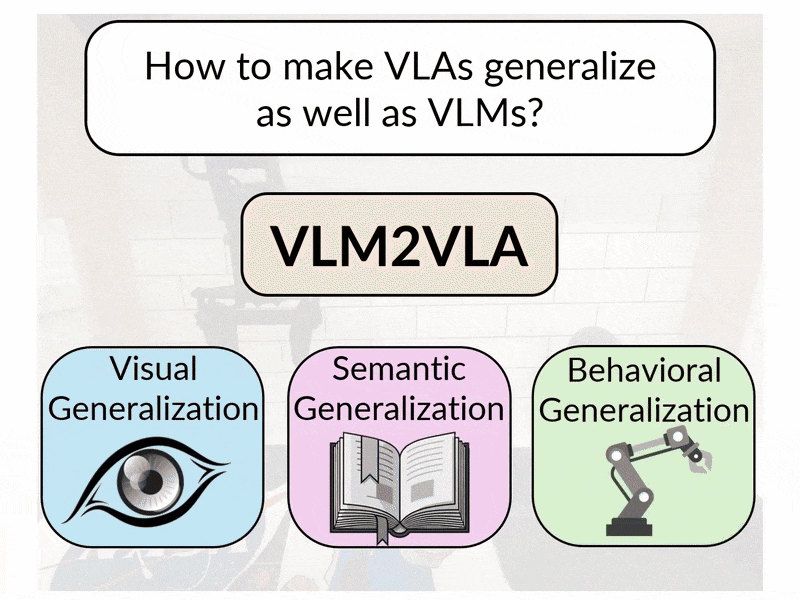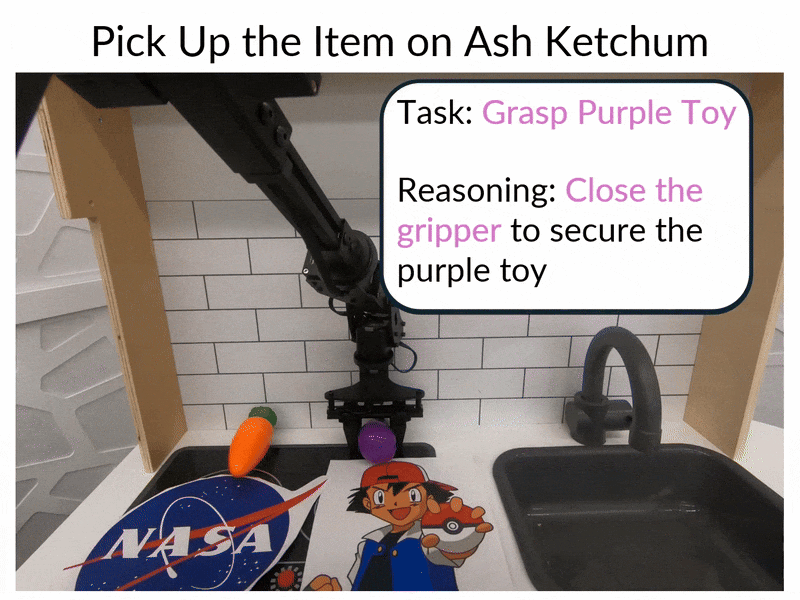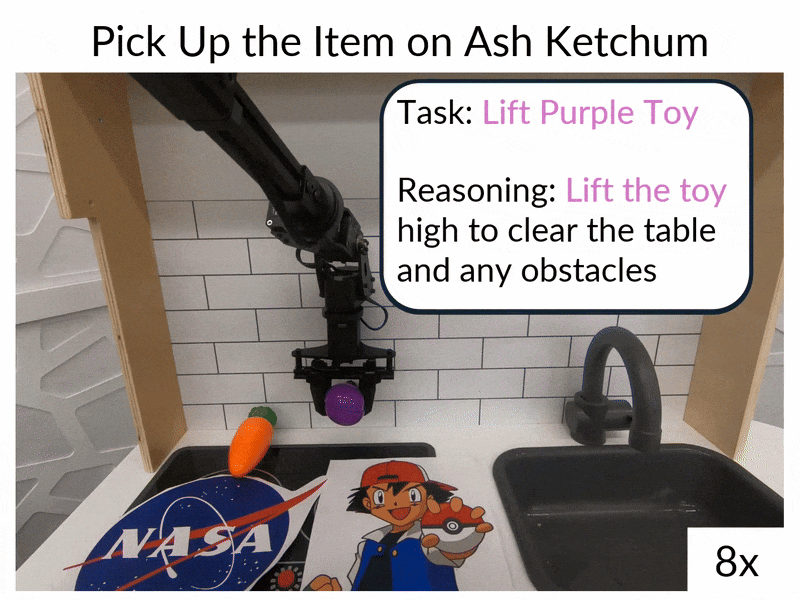
TL;DR: We introduce EgoLAP, a vision-language-action pre-training framework that learns from egocentric human and robot trajectories through shared language actions and motion-level reasoning. EgoLAP transfers human experience to robot control, achieving 80.1% mean real-world task progress on an unseen robot configuration and a 2.3× gain over alternative action representations.
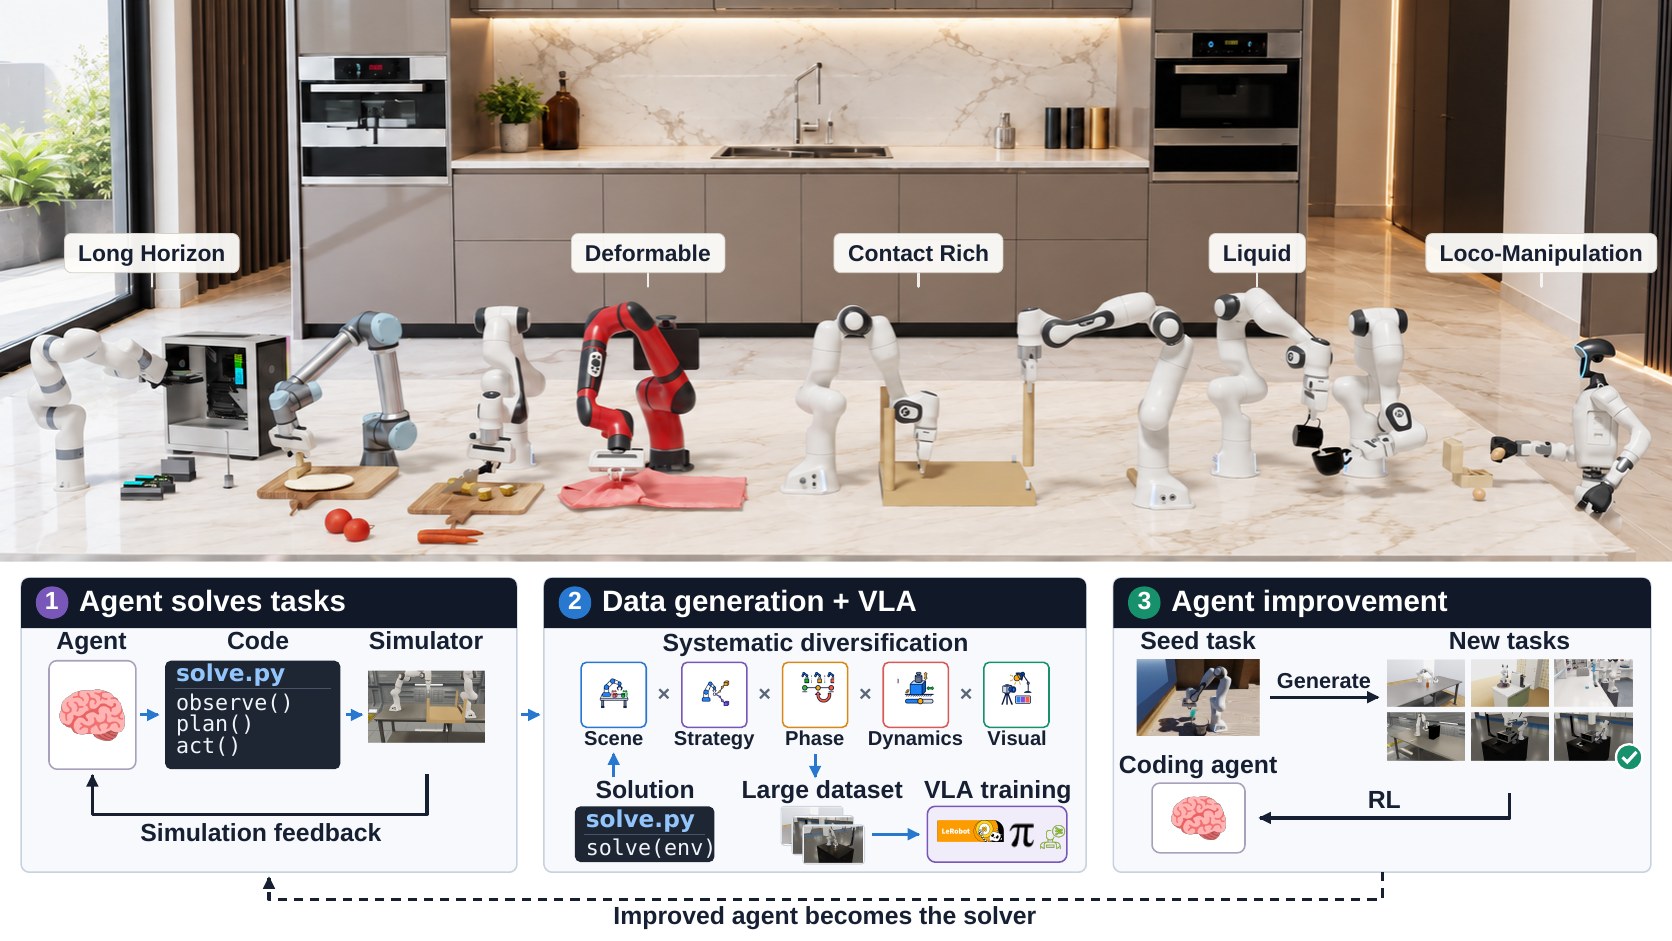
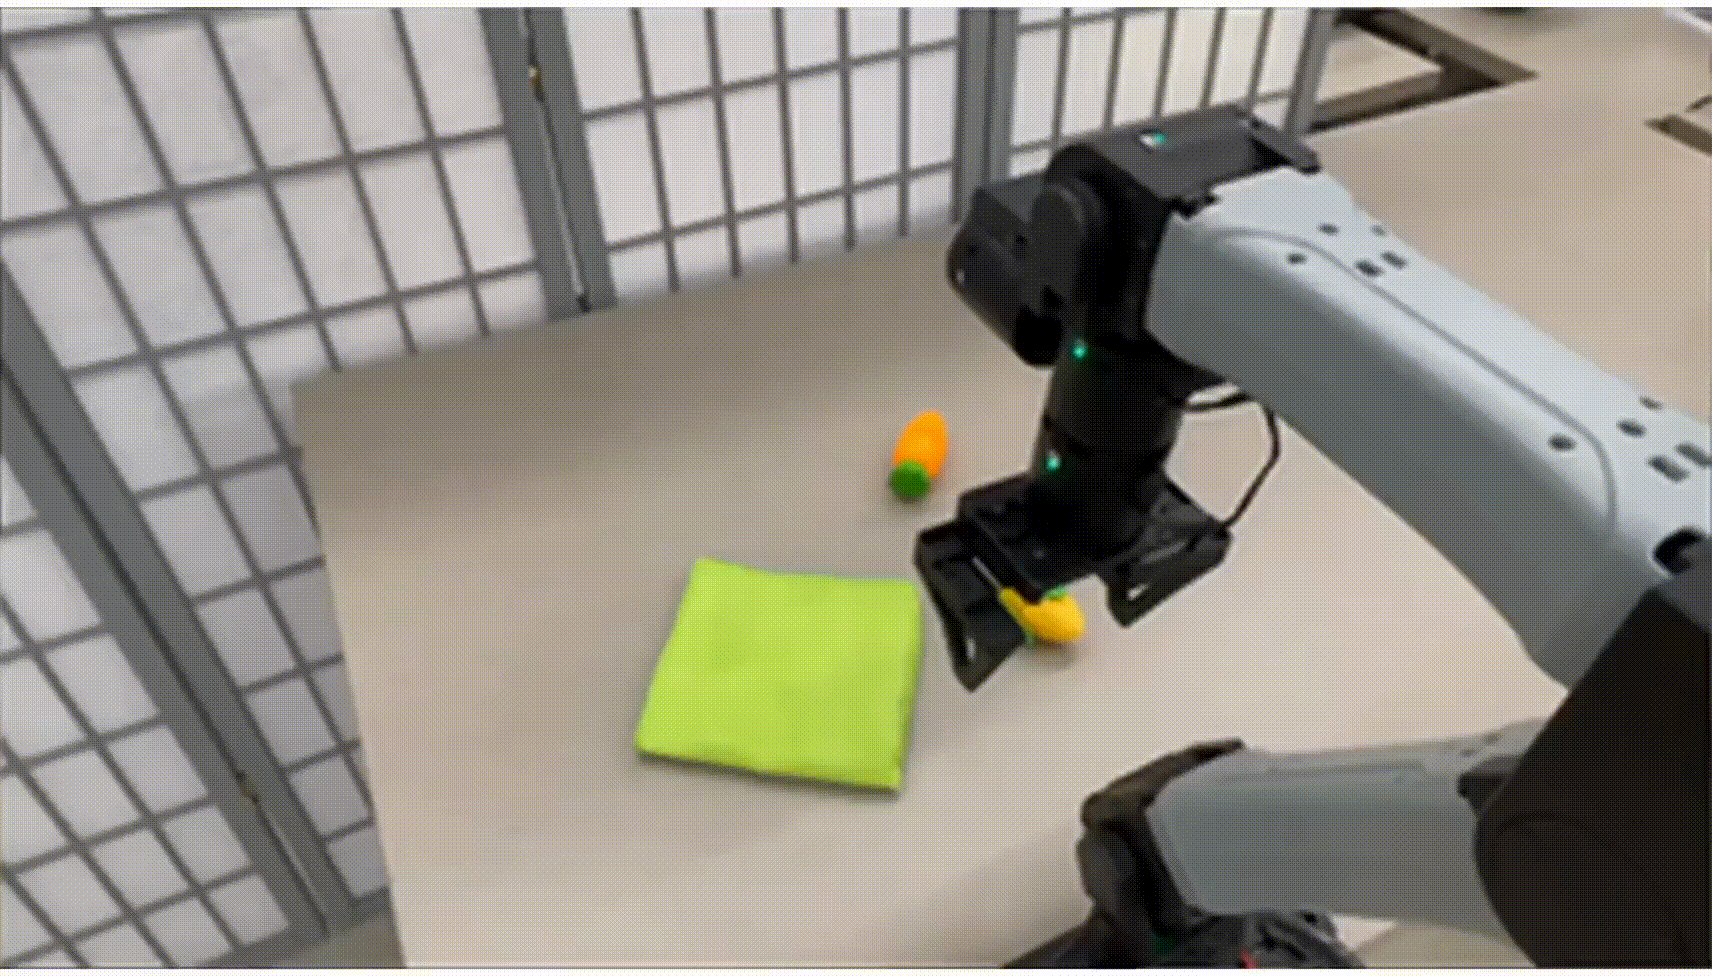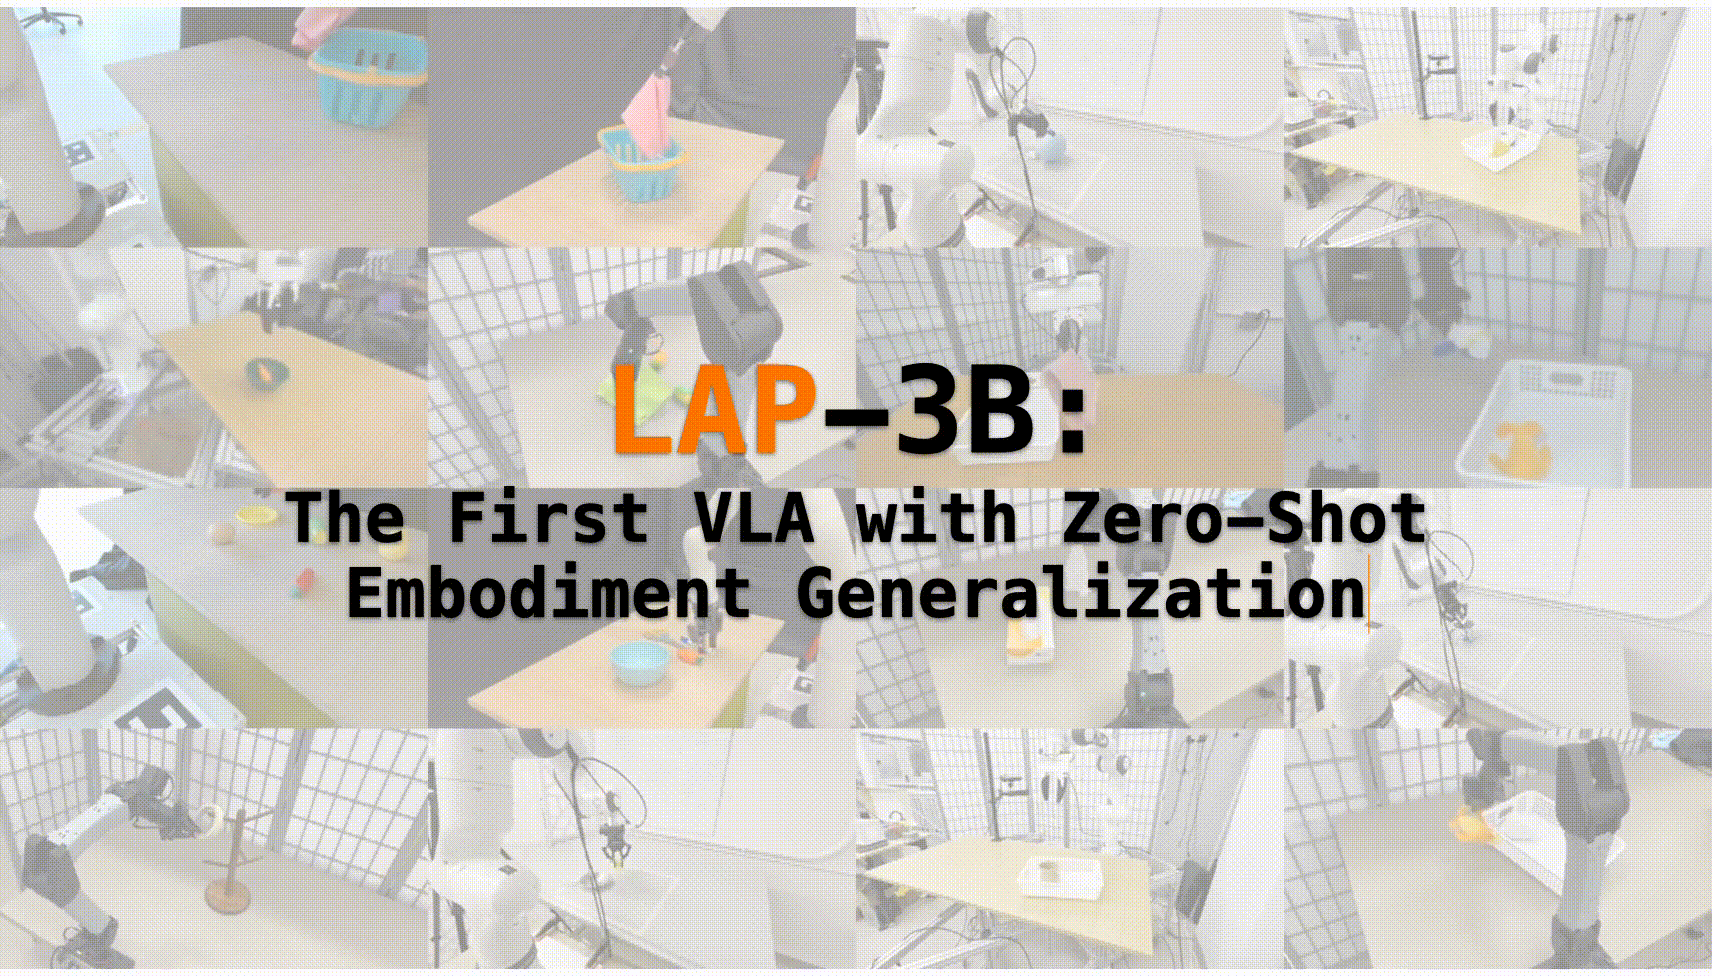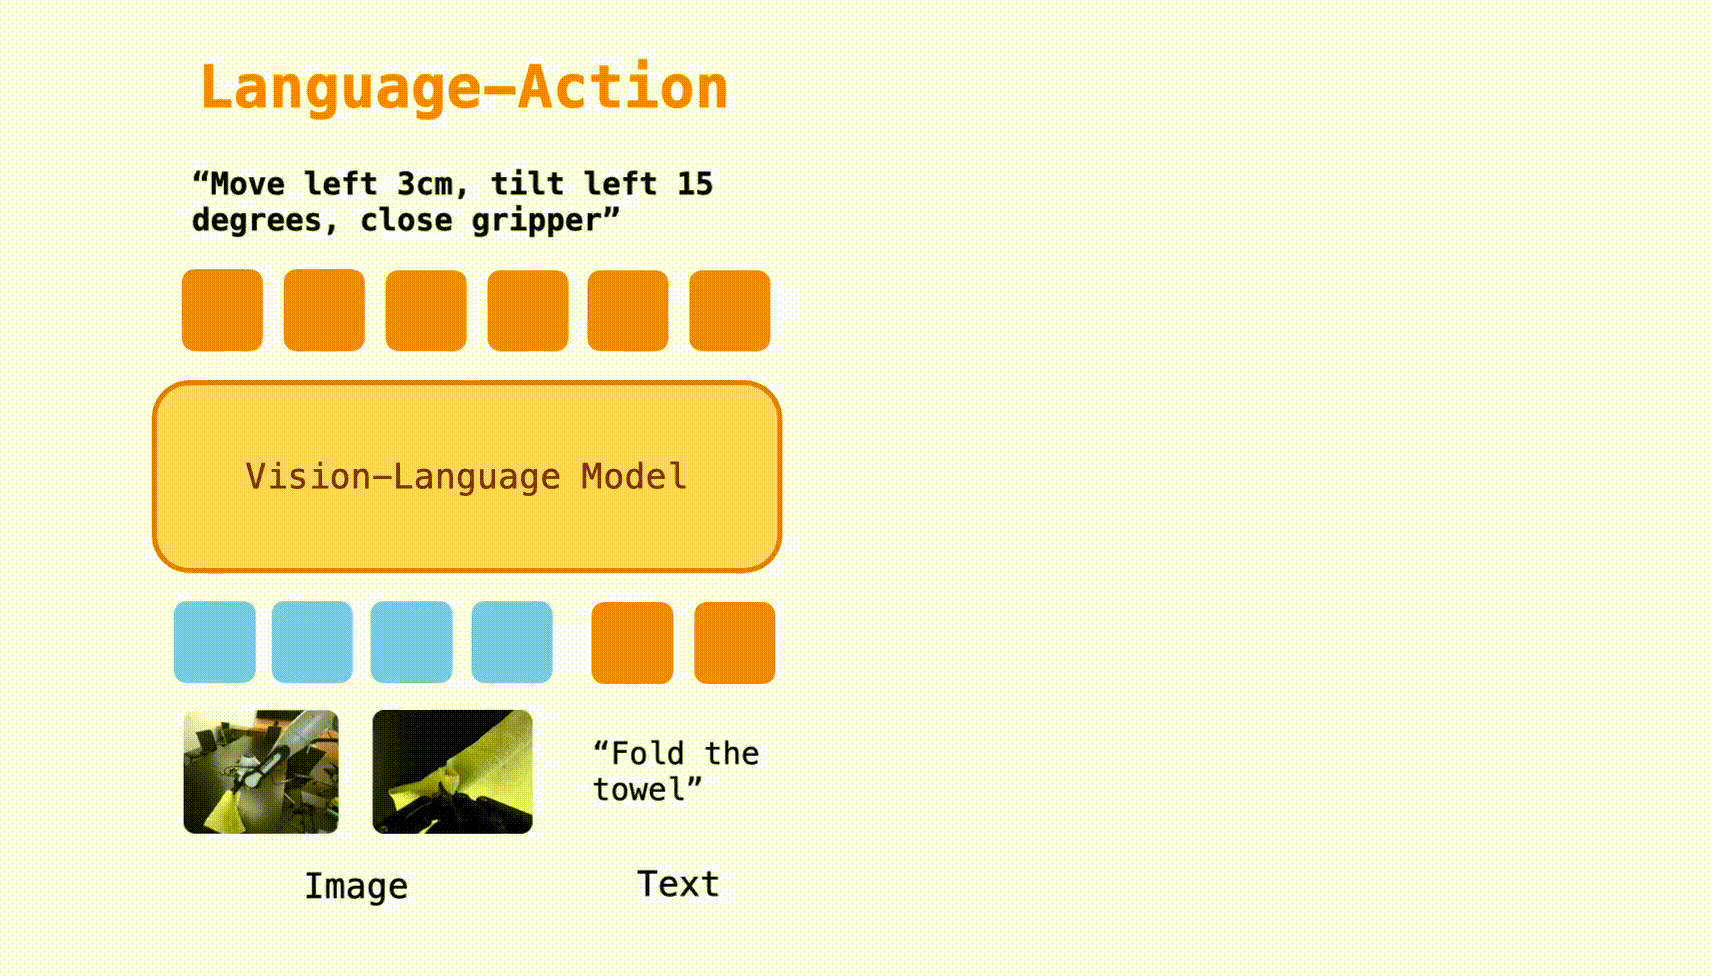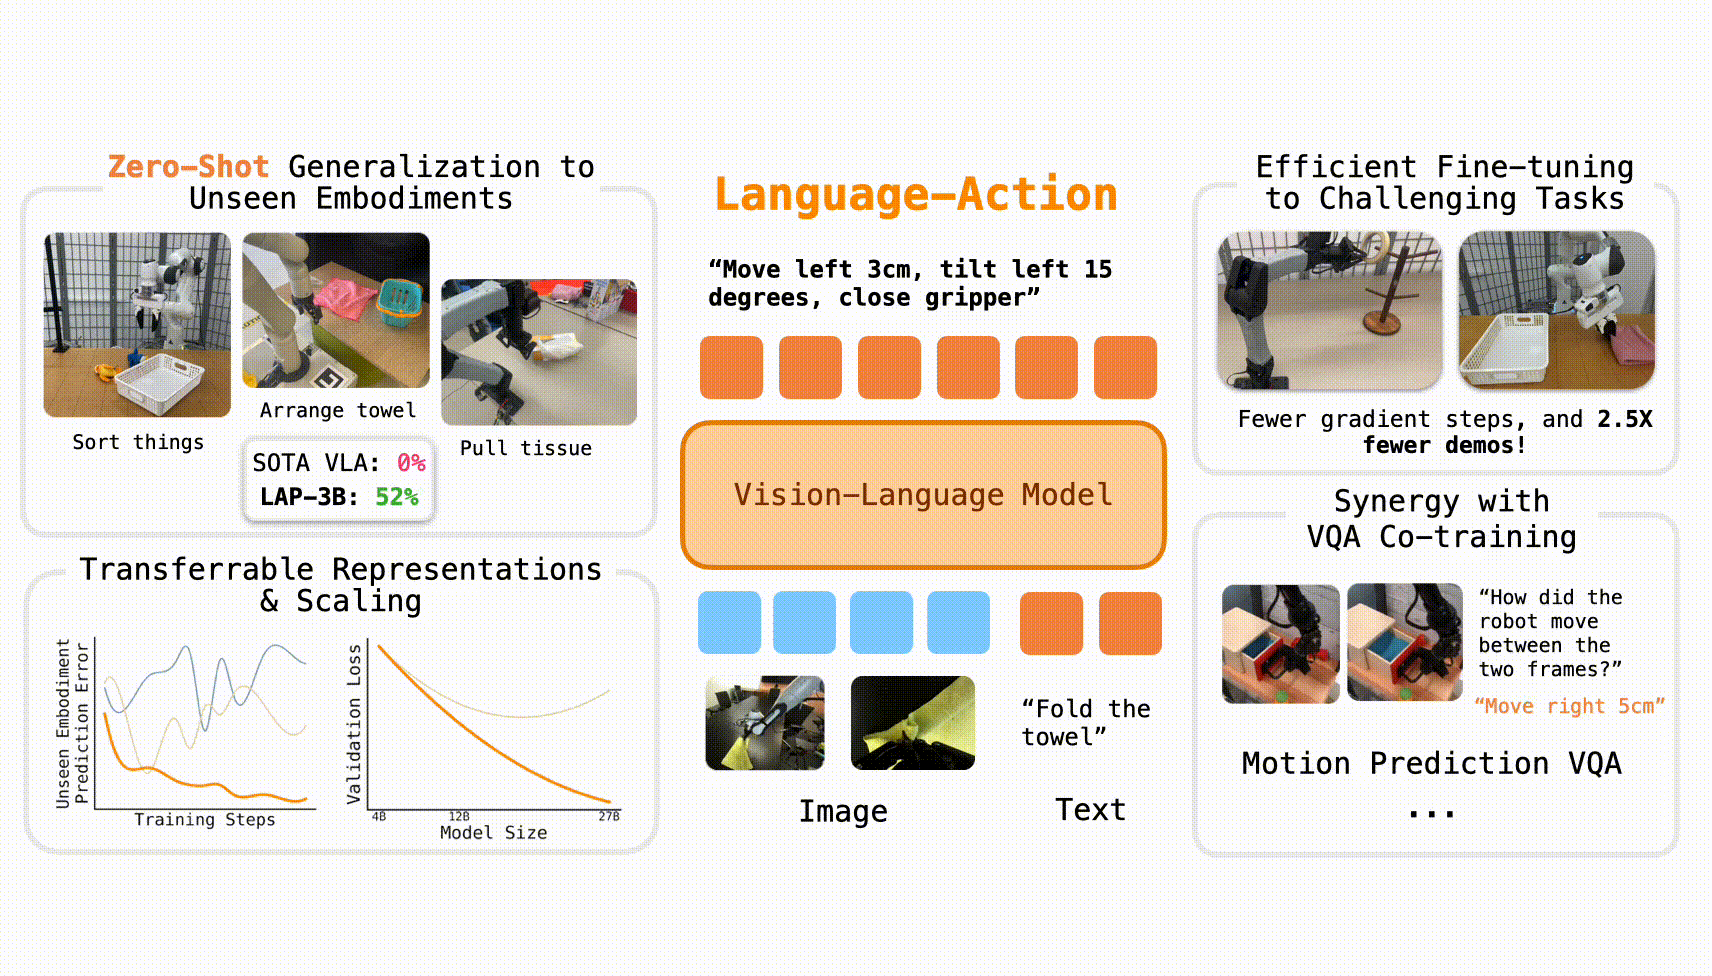
Project image for LAP: Language-Action Pre-Training Enables Zero-shot Cross-Embodiment Transfer

LAP: Language-Action Pre-Training Enables Zero-shot Cross-Embodiment Transfer

Lihan Zha, Asher J. Hancock*, Mingtong Zhang*, Tenny Yin, Yixuan Huang, Dhruv Shah, Allen Z. Ren†, Anirudha Majumdar†

RSS 2026 Robotics: Science and Systems, 2026

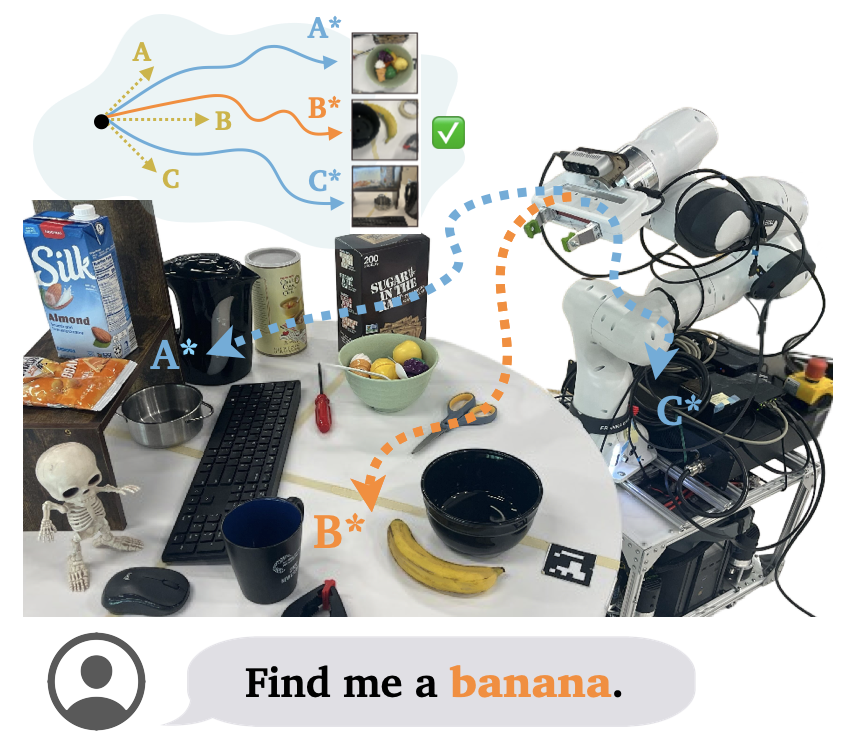
TL;DR: We introduce Language-Action Pre-training (LAP), which represents robot actions as natural language tokens to enable vision-language-action models to transfer zero-shot to new robot embodiments, achieving over 50% zero-shot success on novel robots—approximately twice the performance of prior methods.